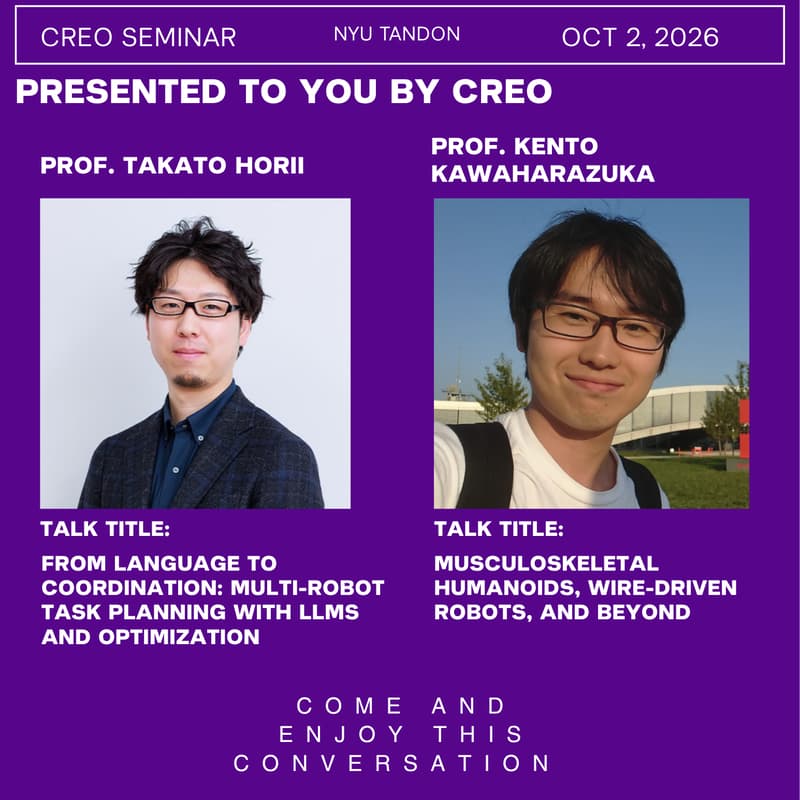
Robotics Seminar Event
Welcome to the Robotics & Embodied Intelligence Seminar!
Join us for an engaging session exploring how AI, robotics, and wireless innovation are converging to transform the physical world. This hybrid event will be held at 370 Jay St and online mark your calendars and don’t miss this opportunity to connect with leading researchers shaping the future of intelligent machines. Whether you’re a student, professional, or enthusiast, this seminar offers a front-row seat to the breakthroughs redefining how robots sense, learn, and act.
About the Seminar: You will be entertained by 2 dynamic speakers!!
1st Speaker: Takato Horii
Title: From Language to Coordination: Multi-Robot Task Planning with LLMs and Optimization
Abstract:
How can robots with different capabilities coordinate their actions to carry out natural language instructions? In this talk, I will introduce LiP-LLM, a multi-robot task planning framework that integrates large language models, dependency graphs, and linear programming. The framework uses LLMs to select skills from a predefined repertoire and infer their ordering dependencies, while linear programming handles task allocation across robots. This separation enables independent tasks to be executed in parallel while respecting the inferred dependencies and robot capabilities. I will present simulation results involving robot arms and mobile robots, showing improvements in task success and plan efficiency compared with existing LLM-based planners. I will also discuss the benefits and limitations of combining language-based reasoning with optimization, as well as challenges in extending this approach to real-world robot teams.
Bio:
Takato Horii is an Associate Professor in the Graduate School of Engineering Science at The University of Osaka, Japan. He received his M.Eng. and Ph.D. degrees from Osaka University in 2013 and 2017, respectively. His research spans robot learning, cognitive developmental robotics, symbol emergence, human-robot interaction, and computational approaches to emotional development. His recent work investigates how foundation models can support robot action planning and how multimodal learning can contribute to embodied intelligence. https://www.takatohorii.jp/
2nd Speaker: Kento Kawaharazuka
Title: Musculoskeletal Humanoids, Wire-driven Robots, and Beyond
Abstract
In this talk, I will provide an overview of our research on biomimetic musculoskeletal humanoids, including Kengoro and Musashi, as well as non-biomimetic wire-driven robots that leverage their muscle-like tendon mechanisms. I will also discuss learning-based control methods for these robotic systems. Furthermore, I will introduce our open-source hardware initiatives aimed at democratizing quadruped robots, bipedal robots, manipulators, and wire-driven robotic systems.
Bio
Kento Kawaharazuka is a Junior Associate Professor at the Next Generation Artificial Intelligence Research Center, The University of Tokyo. He received his B.E., M.S., and Ph.D. degrees in Mechano-Informatics from the University of Tokyo in 2017, 2019, and 2022, respectively. His research interests include musculoskeletal humanoids, tendon-driven robots, machine learning, foundation models, and open-source robot hardware. He delivered a plenary talk at IEEE-RAS Humanoids 2024 and a keynote talk at IEEE ICRA 2026. https://haraduka.github.io/
Visitor Information
This event is open to NYU students, faculty, and staff.
📍 Location: NYU Tandon School of Engineering,
370 Jay St 2th Floor Room 202
Zoom Link: https://nyu.zoom.us/j/97042144832
Meeting ID: 970 4214 4832
About the Robotics & Embodied Intelligence Series
The Robotics & Embodied Intelligence Seminar Series highlights the interdisciplinary work happening across NYU Tandon’s robotics ecosystem — uniting AI, mechanical systems, mechatronics, and wireless technologies.
From bio-inspired locomotion and AI4CE Lab’s autonomous construction research to Machines in Motion’s dynamic control and Bio mechatronics Lab’s assistive robotics, each session offers a deep dive into the innovations reshaping how humans and machines interact.