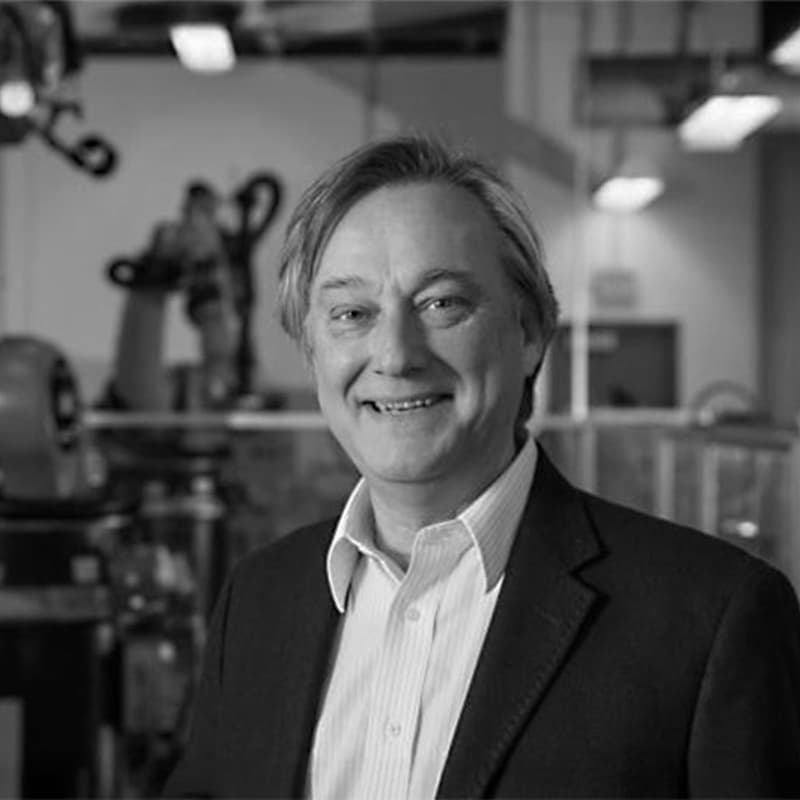

Seth Hutchinson: Model-Based Methods in Today's Data-Driven Robotics Landscape | Priors #02
Priors is a new robotics research group in Boston.
Everyone arrives with beliefs of where the field is going - their Priors. Our mission is to update those Priors through lectures, lightning talks, and paper discussions.
--
For Priors #02, Seth Hutchinson joins us to talk about the robotics problems that resist data-driven methods, and what to do about them.
Learned methods have pushed grasping, locomotion, and perception forward fast. But for some problems, data is expensive, slow, or dangerous to collect. Simulation struggles with nondeterminism and complex dynamics. Demonstrations break down out of distribution and offer no performance guarantees. Seth will walk through recent work where model-based approaches deliver instead: flapping flight on a bat-like robot, vision-based control of soft continuum robots, a cable-driven graffiti-painting robot, and safe mobile manipulation around people. He'll also show where learned tools can still make those methods better.
Seth is a Professor at Northeastern, jointly in Khoury College of Computer Sciences and the College of Engineering, and works with the Institute for Experiential Robotics. His research spans motion planning, vision-based control, planning under uncertainty, physical HRI, locomotion, and bio-inspired robotics, with 300+ publications over three decades. Before Northeastern he spent 28 years at UIUC and seven at Georgia Tech, where he was executive director of the Institute for Robotics and Intelligent Machines. He is a past president of the IEEE Robotics and Automation Society and former editor-in-chief of IEEE Transactions on Robotics.
What to expect:
Technical Lecture Format: First, our speaker will outline the details of their recent work and research (40min). After the structured talk, the floor will remain open for free-flowing Q&A (15min) and casual conversations/networking following.
Logistics: Please arrive on time as the lecture will start promptly!
--
If you spend your days building or researching world models, VLAs, diffusion policies, tactile sensing, teleoperation, dexterous manipulation, HRI, or online RL, this is the room for you.