
Building the future of Physical AI in Berlin
BRISA Reading Group 06 - Long-WAM: Scaling the Context of World-Action Models
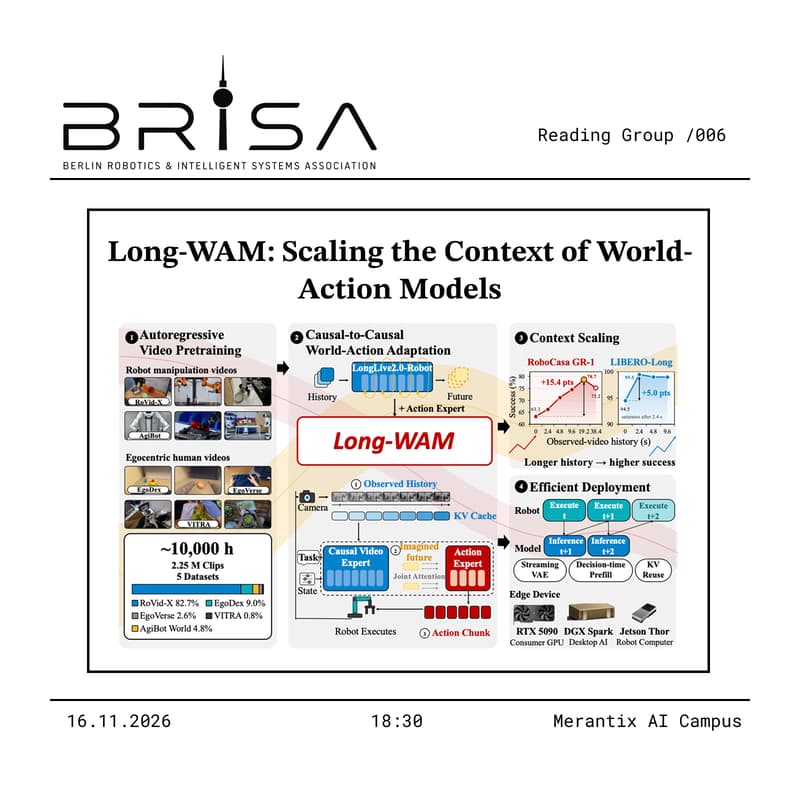
This week we look at Long-WAM: Scaling the Context of World-Action Models (Huang et al., 2026) from NVIDIA, MIT, HKU and UCSD, with code and model checkpoints released openly.
A robot that only sees the current frame can’t tell whether the cup in front of it is moving, or how far along the task it already is. More visual history sounds like the obvious fix, but history costs time and a robot that thinks too long acts too late.
World-action models predict how the scene will evolve and act on that prediction, instead of mapping images straight to actions. Long-WAM asks how much of the past such a model can actually use.
Their central finding: having the history is not the same as using it. On the RoboCasa GR-1 benchmark, stretching the context from zero to 19.2 seconds lifts success from 63.3% to 78.7%, but only if the underlying video model was pretrained autoregressively.
The recipe: first learn causal prediction from robot and egocentric videos without any action labels, then keep that past-to-future structure while teaching the model to act.
No preparation needed. Everyone is welcome - whatever you study, wherever you study and however much robotics you have done so far.
Come with questions, disagreements or your own guess at how many seconds of the past a robot should remember.
🎟️ There are only a limited number of spots, so we can keep the session personal and interactive. Please register early and only attend if you’ve received a ticket.
📍 Hosted at the Merantix AI Campus on November 16th. Doors open 18:30, we start at 18:45.
👋 New here? Join the community group - everything else gets announced there first.
Building the future of Physical AI in Berlin