
Building the future of Physical AI in Berlin
BRISA Reading Group 01 - Play2Perfect
Before the official launch this fall, we're opening with the thing we want the whole community built around: sitting down with a paper, understanding it properly and asking what it would take to build it ourselves.
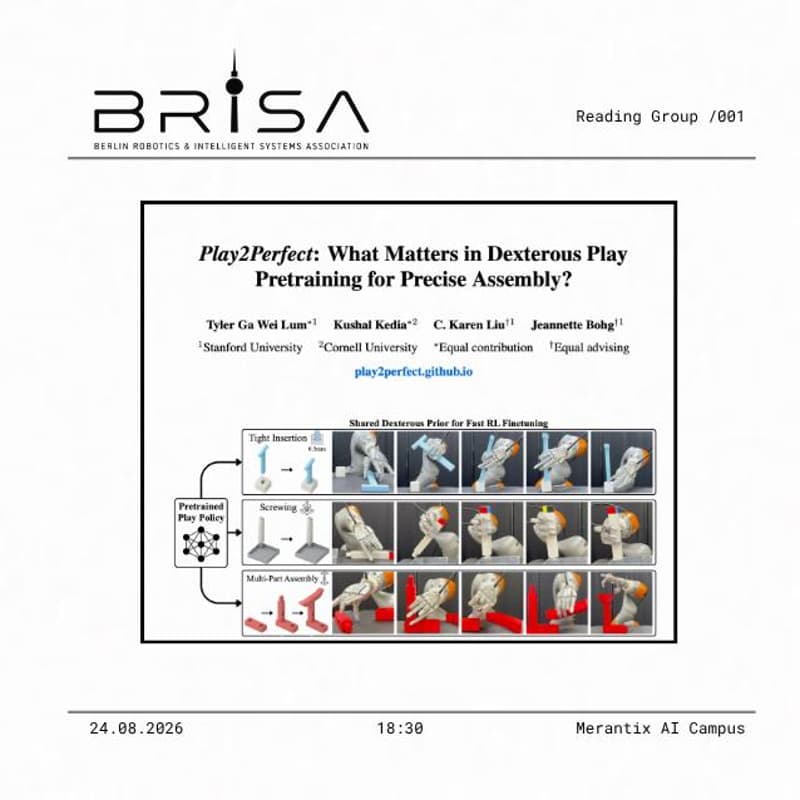
Our first paper is Play2Perfect: What Matters in Dexterous Play Pretraining for Precise Assembly? (Lum, Kedia, Liu & Bohg, 2026) out of Stanford and Cornell, with videos and open code on the project page.
Precise assembly with a five-fingered hand is difficult for two reasons: the tasks are contact-rich, so teleoperating demonstrations is inherently challenging. Additionally, they are sparse-reward, so RL exploration never gets a grasp of success.
An answer might come from the engineering perspective, for instance through building custom grippers, fixtures and tool attachments. However, the authors take a different path: before a robot can perfect assembly, it should first learn to play.
First, a single policy learns in simulation to pick up a thousand random objects and move them to random target poses. No demonstrations and cues on what the real task will be.
Then that same policy is finetuned on the actual assembly, told nothing except whether it succeeded.
It then runs on a real robot arm and hand with no further training, fitting a T-shaped block into a hole half a millimetre wider than the block itself.
We selected this paper for our first session for a very specific reason. Everything needed is there: object generation, reward terms, hyperparameters, the full compute setup, 3D printable parts, code on GitHub and videos.
We have seen the potential of this paper - with all its auxiliary material, a team could take it from the first line to a working system.
This gap - between reading a robotics paper and building the thing - is what BRISA exists to bridge.
No preparation needed. Skim the abstract if you have ten minutes, watch the videos if you have two. Everyone is welcome - whatever you study, wherever you study and however much robotics you have done so far.
Come with questions, with disagreements, or with something you want to build.
🎟️ There are only a limited number of spots, so we can keep the session personal and interactive.
📍 Hosted at the Merantix AI Campus. Doors open 18:30, we start shortly after.
👋 New here? Join the community group — everything else gets announced there first.
Building the future of Physical AI in Berlin