
Building the future of Physical AI in Berlin
BRISA Reading Group 09 - RoboStriker: Hierarchical Decision-Making for Autonomous Humanoid Boxing
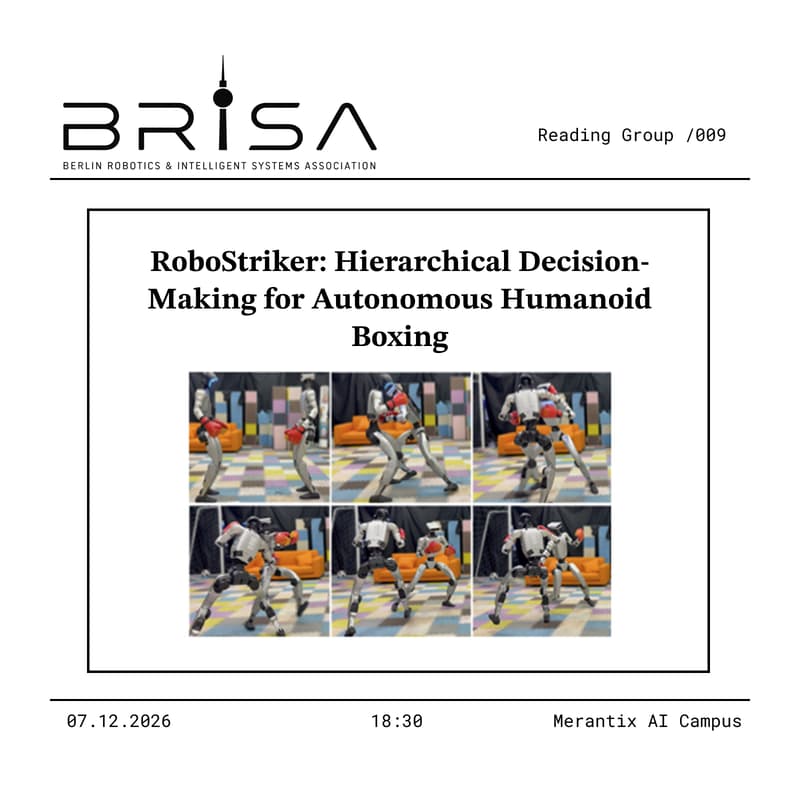
To close November we look at RoboStriker: Hierarchical Decision-Making for Autonomous Humanoid Boxing (Yin et al., 2026) from Shanghai Jiao Tong University.
Most humanoid research is about the robot and the world: walking, balancing, picking things up. Boxing adds an opponent who is actively trying to knock you over.
Multi-agent RL is the textbook framework for this kind of strategic interaction. Applied directly to 29 motors, though, it struggles: there are far too many ways to move that aren’t boxing or aren’t even standing.
RoboStriker splits the problem in three. First, a motion tracker learns professional boxing moves from human motion capture on a Unitree G1. Those skills are then compressed into a compact latent space, projected onto a hypersphere so that every point in it is a physically plausible motion. Finally, two agents learn tactics through self-play, choosing points in this skill space instead of raw joint commands.
First learn to move, then learn to fight. The result outperforms the baselines in simulation and transfers to the real robot.
The same pattern keeps showing up in robot learning, from Play2Perfect to here. Learn a vocabulary of good movements first, then plan in it. How much does that limit what a robot can discover?
Skim the abstract if you have ten minutes, watch the videos if you have two. Everyone is welcome - whatever you study, wherever you study and however much robotics you have done so far.
Come with questions, disagreements, or your best guess at when we’ll see the first robot boxing match.
🎟️ There are only a limited number of spots, so we can keep the session personal and interactive. Please register early and only attend if you’ve received a ticket.
📍 Hosted at the Merantix AI Campus on December 7th. Doors open 18:30, we start at 18:45.
👋 New here? Join the community group - everything else gets announced there first.
Building the future of Physical AI in Berlin