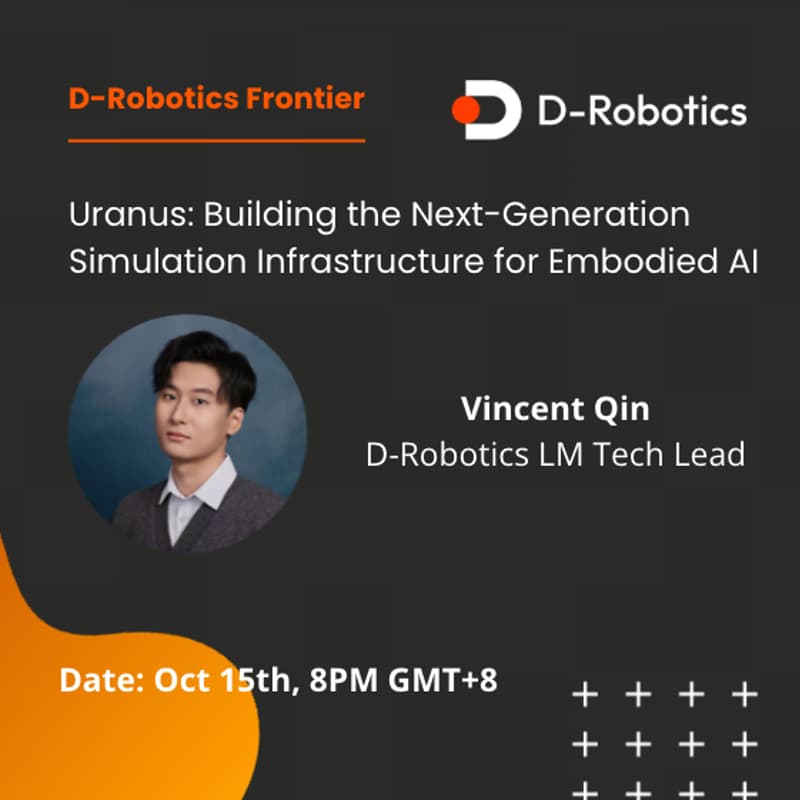
D-Robotics Frontier — #1 Uranus
D-Robotics Frontier
D-Robotics Frontier is a technical series where we share the latest advances, research, and engineering breakthroughs from D-Robotics.
Through this series, we share cutting-edge technologies, research progress, and engineering breakthroughs from D-Robotics, spanning Embodied AI, world models, robot learning, and intelligent robotics.
More than a showcase of what we’ve built, Frontier is a space for deep technical exchange — bringing together researchers, engineers, developers, and robotics enthusiasts to explore new ideas, challenge assumptions, and shape what comes next in robotics.
# 1 Uranus
Real-robot validation is costly and hard to reproduce. Classic simulators require laborious modeling — and still struggle with the sim-to-real gap.
We’re building a different route.
Meet Uranus — a data-driven, interactive simulation platform for robot development, powered by an Interactive World Model at its core.
On October 15, we’re hosting a technical webinar to open up the full stack behind Uranus.
Curation and calibration recovery over 3,300 hours of real robot data,
Causal training and distillation of a 1.3B model
The serving infrastructure that brings one inference step to 24 FPS — together with measured long-horizon consistency, closed-loop policy evaluation, and cross-embodiment generalization, plus an honest account of where it still breaks.
Code, weights, and data are open-sourced.
📅 October 15th, 20:00 GMT+8
🎙️ Speaker: Vincent Qin | LM Tech Lead at D-Robotics
Speaker bio: Vincent Qin is the LM Tech Lead at D-Robotics. He holds a master's degree from Peking University and previously worked at Baidu, SenseTime, and NIO, where he successively led work in computer vision algorithms and multimodal perception. Later, at GigaAI, he was responsible for deploying world models for leading domestic OEMs, and for building robot perception and VLA algorithms. He currently focuses on video world model R&D at D-Robotics and on building the infrastructure for large-model training and inference.
Feel free to connect with Vincent on LinkedIn: https://www.linkedin.com/in/wenkang-qin-894809327/
Join us to explore the third path for robot simulation to see how an Interactive World Model becomes an engineering-ready simulation platform — and where this new road for robot development can take us.