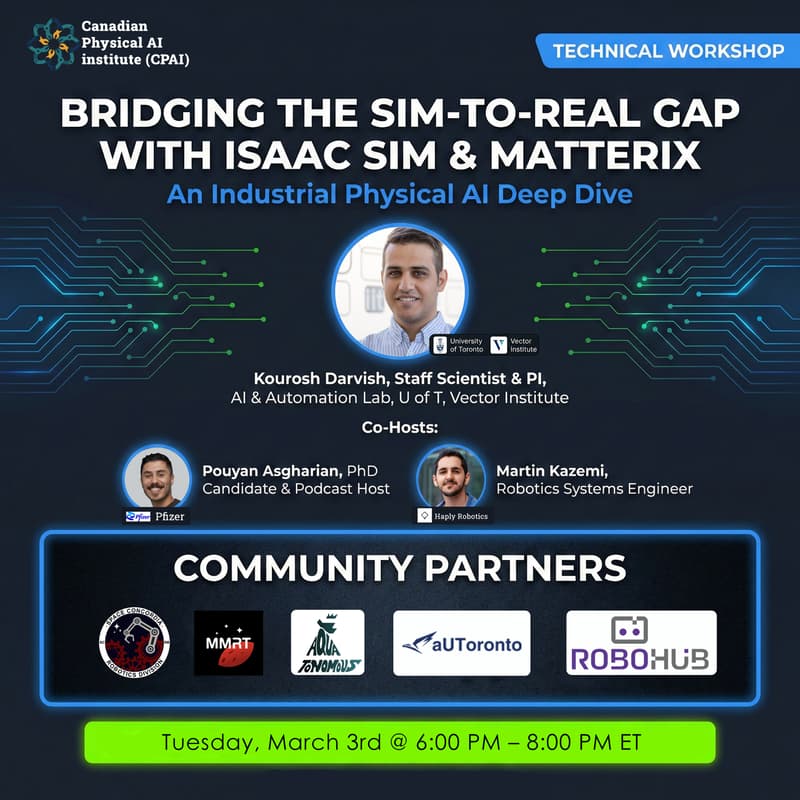

Physical AI: Building High-Fidelity Digital Twins with Matterix
How do we move beyond standard simulation to create high-fidelity digital twins that truly mirror the real world?
Simulation is critical for modern robotics, but the "sim-to-real" gap remains a significant bottleneck, especially in complex environments involving fluids, deformable objects, and chemical processes.
Join the Canadian Physical AI Institute (CPAI) for an exclusive session with Kourosh Darvish, Staff Scientist at the University of Toronto, as we explore Matterix—a new multi-scale, GPU-accelerated simulation framework designed to create high-fidelity digital twins.
While originally developed for chemistry laboratory automation and self-driving labs, the concepts covered are broadly applicable to robotics domains requiring complex manipulation and perception.
🚀 What You Will Learn
This session is designed to provide both a "behind-the-scenes" look at real research projects and a practical walkthrough of key concepts.
Introduction to Matterix: Discover a framework built on NVIDIA Isaac Sim and Isaac Lab that integrates realistic physics and photorealistic rendering with a modular, GPU-accelerated semantics engine.
Multi-Scale Modeling: Learn how to simulate beyond simple rigid bodies, including powder and liquid dynamics, device functionalities, heat transfer, and chemical reaction kinetics.
Hybrid Intelligence: Explore how to model both logical states and continuous behaviors to represent workflows across multiple levels of abstraction.
Digital Twin Value: Gain a clear view of where digital twins add value, specifically in policy training, workflow development, system co-design, and safety analysis
Real-World Tradeoffs: An honest discussion on when simulation works well, when it breaks down, and how to navigate those tradeoffs in real projects.
📅 Agenda (ET)
6:00 PM | Part 1: Introduction to Matterix
Deep dive into creating high-fidelity digital twins using open-source asset libraries and standardized interfaces.
How to enable flexible workflow design via hierarchical planning and modular skill libraries.
Examples of modeling complex material interactions, from robot manipulation to perception.
6:45 PM | Part 2: Simulation for Robot Learning
How Matterix and Isaac Sim support data generation for robot learning workflows.
Addressing cases where standard simulation abstractions fall short in lab environments.
7:30 PM | Open Discussion & QA
A hybrid discussion involving academia and industry on the "real-to-sim" gap.
Key Discussion Points:
Creation of high-fidelity assets using generative models and 3D computer vision.
Augmenting simulation with synthetic data and world models to improve realism and transferability.
How industry practitioners can leverage digital twins for design, testing, and maintenance.
👨💻 Who Should Attend?
This event is intentionally designed to be useful for both beginners and experienced users:
Beginners: Gain exposure to modern robotics simulation pipelines and current research directions.
Industry Practitioners: Those looking to add flexibility, generalization, and faster iteration to real-world robotic systems.
Researchers & Students: Anyone working on robot learning, digital twins, embodied AI, or self-driving laboratories.
🎙 About the Speaker
Kourosh Darvish is a Staff Scientist and Principal Investigator at the AI & Automation Lab, University of Toronto. His work focuses on the intersection of physical AI, simulation, and real-world robotic deployment.
Yuchi (Allan) Zhao | PhD Student Allan is a PhD student at the Matter Lab (University of Toronto) and the Vector Institute. With a background in Computer Vision and Mechatronics , his research focuses on building robots that leverage multimodal inputs—vision, language, and touch—to adapt quickly to unstructured environments.
Focus: Self-driving laboratories and accelerating materials discovery.
Highlight: He will be presenting his latest work on AnyPlace, demonstrating how to bridge the sim-to-real gap for complex manipulation tasks.
🎤 Meet the Hosts
This session will be moderated by:
Pouyan Asgharian | PhD Candidate
Pouyan is a Robotics Engineer at Pfizer and a PhD candidate at Université de Sherbrooke, working at the intersection of automation, AI, and human-robot interaction.
Martin Kazemi | Robotics Systems Engineer
Martin is a Robotic Systems Engineer at Haply Robotics with a background in Mechatronics and Physical AI. He has previously worked on robotics initiatives at Meta and the National Research Council Canada, specializing in robot calibration and automation.
🤝 Community Partners
We are excited to be joined by Canada’s top student robotics teams who are pushing the boundaries of autonomous systems and field robotics:
McMaster Mars Rover (McMaster University) Focused on the design and operation of high-performance planetary rovers. mcmastermarsrover.com
aUToronto (University of Toronto) Developing champion-level autonomous driving software and self-driving vehicles. autoronto.ca
aQuatonomous (Queen's University) Engineering autonomous surface vehicles (ASVs) for complex aquatic environments. aquatonomous.vercel.app
Space Concordia (Concordia University) Innovating in space robotics and rover systems through their dedicated Robotics Division. spaceconcordia.ca
The Waterloo RoboHub - Robotics at Waterloo(University of Waterloo) an interdisciplinary robotics group within the Faculty of Engineering at the University of Waterloo. https://uwaterloo.ca/robohub/
📚 Recommended Pre-Reads (Official NVIDIA Resources) To help you get the most out of this deep dive, we recommend exploring these official resources from our ecosystem partners:
NVIDIA Robotics Learning Path: A comprehensive guide to mastering the Isaac ecosystem. [Link: https://www.nvidia.com/en-us/learn/learning-path/robotics/]
Isaac Sim Developer Hub: The core documentation for the simulation tools we will be discussing. [Link: https://developer.nvidia.com/isaac/sim]
Hosted by: Canadian Physical AI Institute (CPAI)
Format: Live on Google Meet (Link provided upon registration).
Can't make it live? Register to receive the recording and technical resources after the event.